TEAM VOLTEDGE
DRIVEN BY VOLTS, DEFINED BY VISION.
DRIVEN BY VOLTS,DEFINED BY VISION.
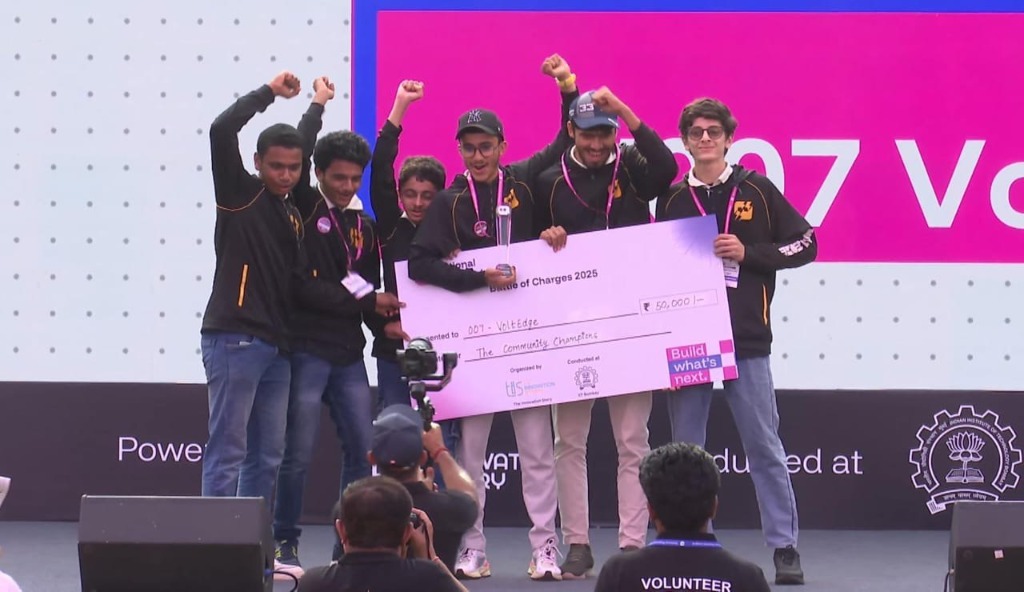
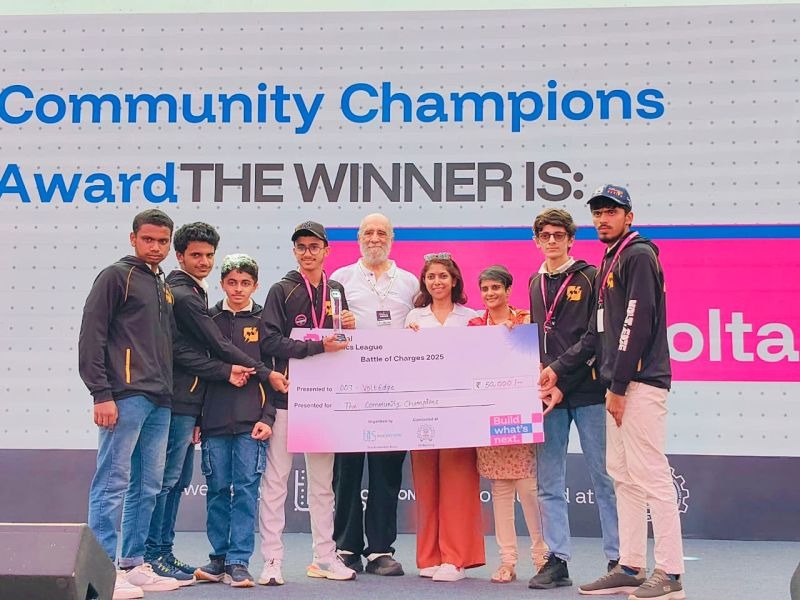
Honored on stage at the Indian Institute of Technology Bombay, Powai for winning the Community Champions Challenge by demonstrating outstanding outreach efforts to promote STEM education and making robotics accessible to young learners in our community.
From a small coastal town to India's premier national robotics arena at IIT Bombay. Assembled in a six-day sprint by six twelfth-grade engineers, Team VoltEdge (Team ID 007) re-engineered the competition BaseBot into EdgeBot — a high-torque, sensor-fused machine featuring closed-loop gyroscope stability, autonomous line-following arrays, and custom PWM joystick actuation.
October 22 to 27 rapid assembly
Awarded Team • IIT Bombay Finals
Organic impressions within two weeks
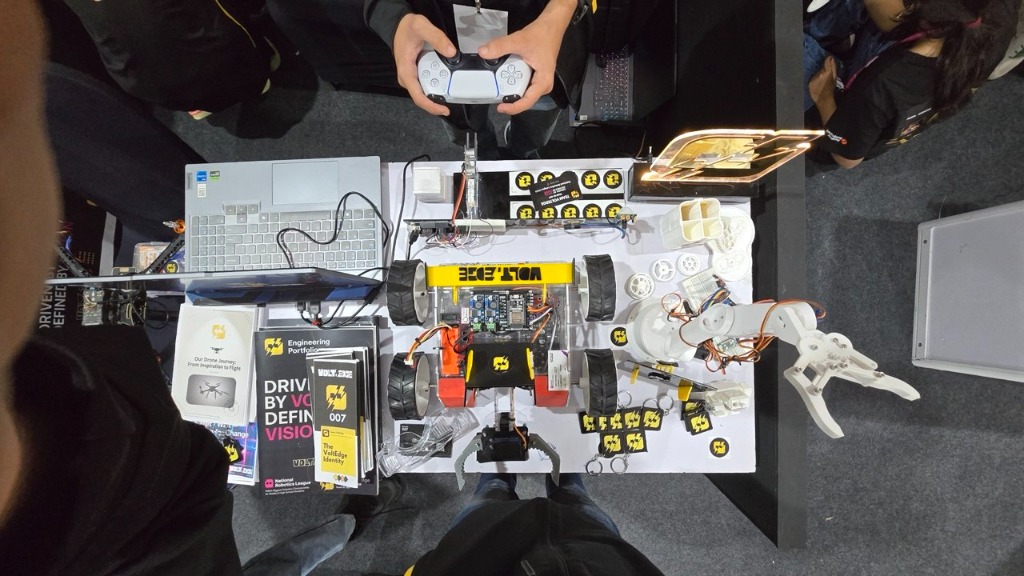
EdgeBot Engineering Specs
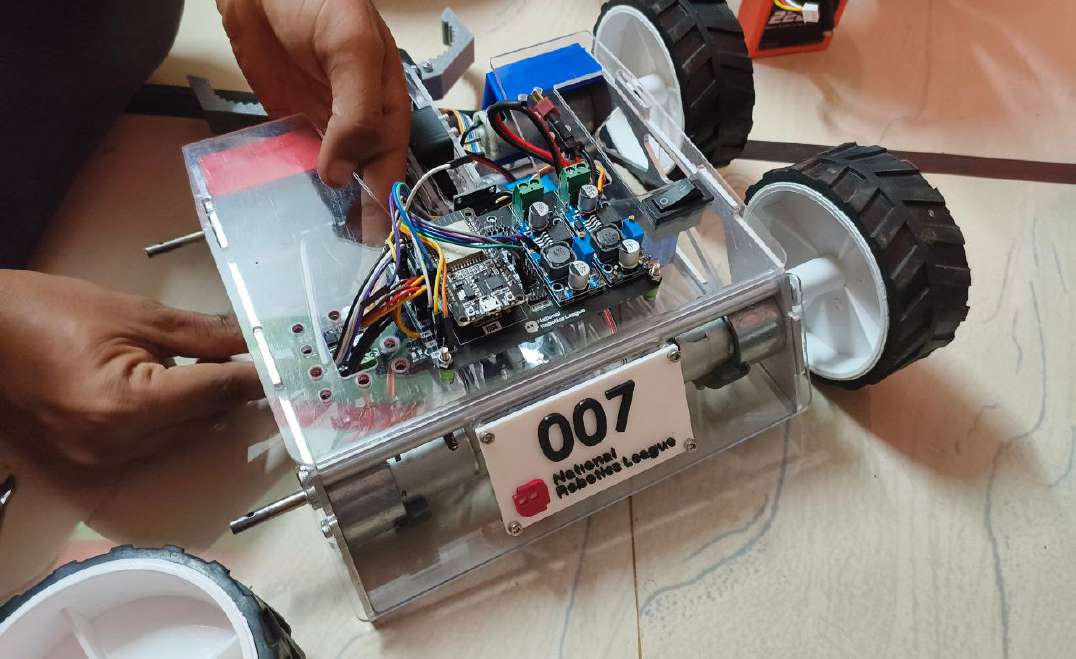
Physical Envelope & Dimensions
Aerodynamic & Structural Modifications
- Custom 3D-Printed Monster Shell: Replaced the open BaseBot skeleton with an impact-resistant body for physical rigidity.
- Rear Aero Wing: Balances high-speed acceleration, minimizes rear chassis lift, and keeps drive wheels grounded during quick directional changes.
- Chassis Downlights: High-visibility underside LEDs illuminate arena floor seams and provide visual diagnostics during drive testing.
PS5 Gamepad Firmware Mapping
The default BaseBot was abrupt with full-up and full-down binary buttons. Lead Programmer Omer Ruknuddin refactored the Arduino C++ firmware to introduce analog PWM trigger curves:
Skill Challenge Sensor Suite
Custom mounted at chassis front to read black tape tracks with high precision thresholding.
Eliminates rotational turn drift, enabling exact ninety-degree pivot turns and reliable straight lines.
Measures distance to slow and stop safely before charging stations without collisions.
The Minds Behind VoltEdge
Minds Behind VoltEdge
Six dedicated twelfth-grade student engineers from the coastal town of Bhatkal, Karnataka, united by a relentless drive for robotics excellence. From designing custom firmware and mechanical chassis assemblies to executing high-pressure match rounds, each member championed a critical engineering domain to claim the national title at IIT Bombay.
VoltEdge 007 — Official Reveal Video
Abdullah Saami Sada
Responsible for executing the end-to-end team engineering workflow, architecting foundational software systems, compiling the comprehensive engineering portfolio, and directing project execution and management. Structured all technical milestones and established the operational cadence of VoltEdge.
- Workflow executor coordinating build sprints, milestones, and technical deliverables
- Lead author and compiler of the National Robotics League Engineering Portfolio
- Architect of the initial software control system and Arduino IDE firmware setup
- Project operations and workflow management directing task execution, deadlines, and technical documentation
- Pit Team operations lead ensuring strict adherence to National Robotics League competition standards
Mohiddin Ahmed Motiya
Directs how VoltEdge is represented to the robotics community, schools, and the public. Curated the official gold and black team apparel and pit presence, and actively hosted the Ali Public School community workshops and Basic Robotics Course sessions. Coordinates on-field charge feeding and zone communications during live competition rounds.
- Brand stewardship: official team jerseys, jackets, identity collateral, and pit display presentation
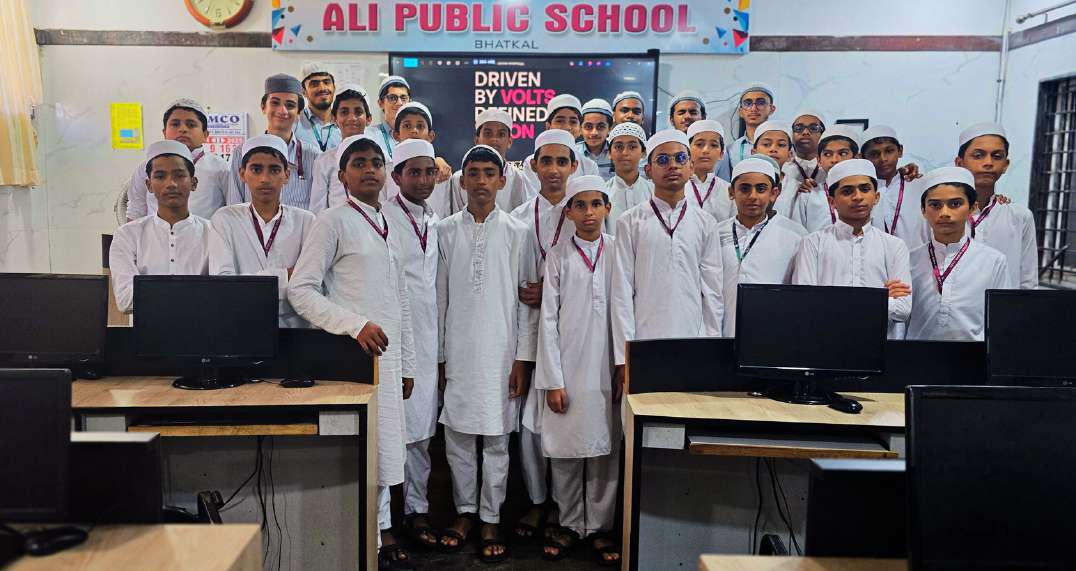
- Master of Ceremonies and lead host for Ali Public School robotics workshops for sixty students
- Coordination and daily hosting of the hands-on community Basic Robotics Course and hardware kit sessions
- On-field Human Player execution during high-speed scoring cycles
Omer Ruknuddin
Architect of the digital core of the robot. Modified and refactored the initial code for superior accessibility, smooth execution, and enhanced driver control — introducing continuous PWM trigger elevation curves and instant claw actuation. Designed and programmed the closed-loop autonomous challenge system integrating the infrared sensor array, gyroscope stabilization, and ultrasonic distance braking. Steers EdgeBot on the competition arena with high field awareness.
- Modified and refactored Arduino C++ code for smooth analog PWM controls and superior driver accessibility
- Programmed the Autonomous Challenge software suite with five-sensor IR line tracking, gyroscope heading, and ultrasonic braking
- Real-time robot piloting and micro-path tactical corrections during match play
- Co-developer of the Remote Drone-Assisted Harvesting agricultural innovation
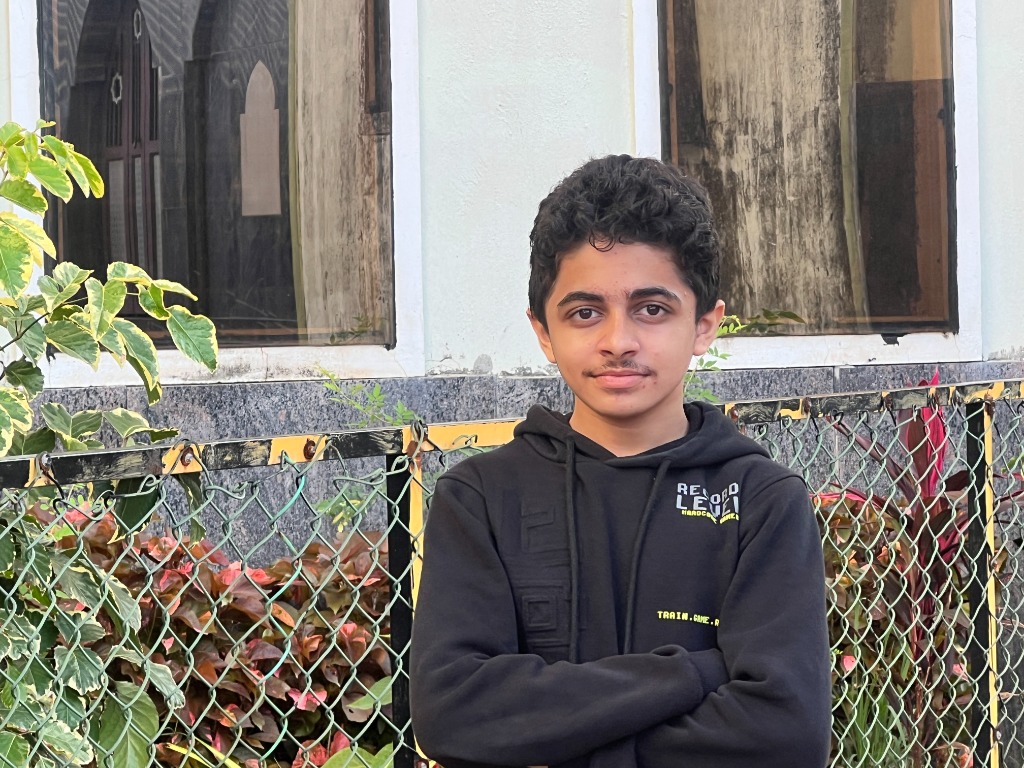
Ahmed Irfan Akrami
Ensures the physical integrity and balance of EdgeBot under high torque. Precision-aligned the dual-layer chassis, eliminated drive drift through balanced axle torque, and designed the Automated Field Shutter System for agricultural weather protection.
- Structural assembly of dual-layer chassis and steel motor bracket mounts
- Torque balancing across all four DC drive motors to eliminate mechanical drift
- Mounting and load-balancing of 3D-printed monster-truck shell and rear aero wing
- Inventor of the sensor-driven Automated Field Shutter System
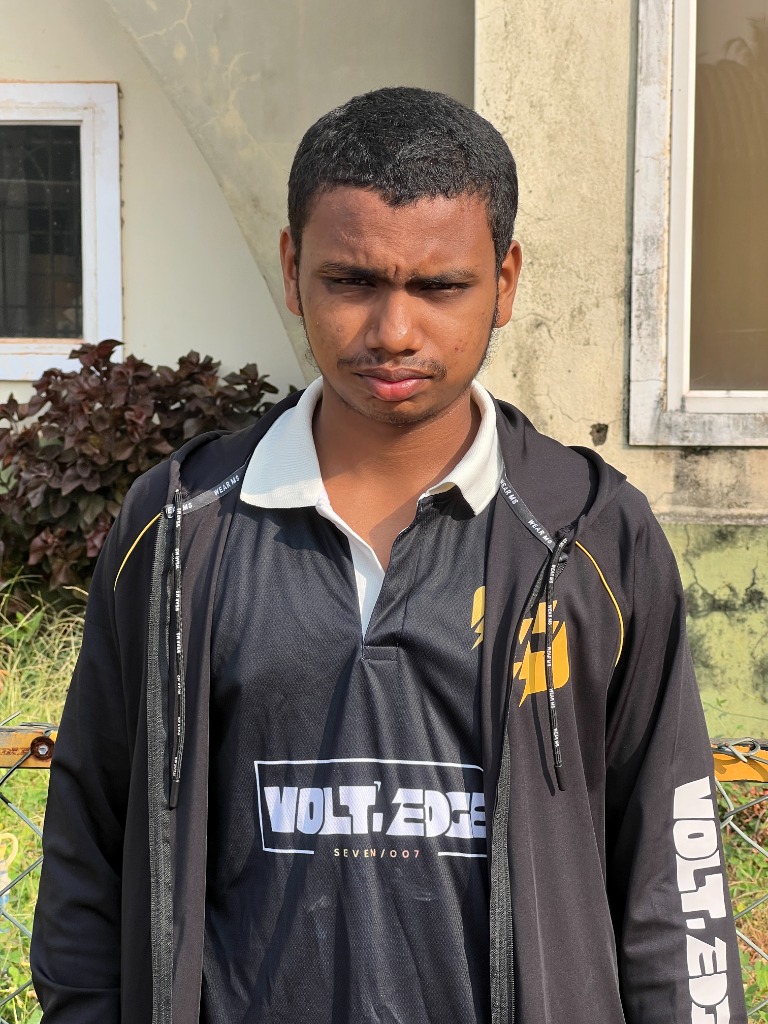
Mohammed Zaid Fareed
The electrical backbone of EdgeBot and Course Peer Tutor for the community outreach program. Designed the wiring topology for the MDD10 motor driver and HEXA ESP32 board, routed cables clear of drive assemblies, and taught foundational robotics, circuit safety, and sensor wiring to sixty students at Ali Public School.
- Course Peer Tutor teaching foundational robotics, circuit safety, and sensor logic during the Basic Robotics Course
- Power routing and cable management across dual-layer acrylic chassis
- Integration of MDD10 dual-channel driver, battery power, and voltage regulation
- Hardware wiring of five-channel IR array, ultrasonic sensor, and gyroscope
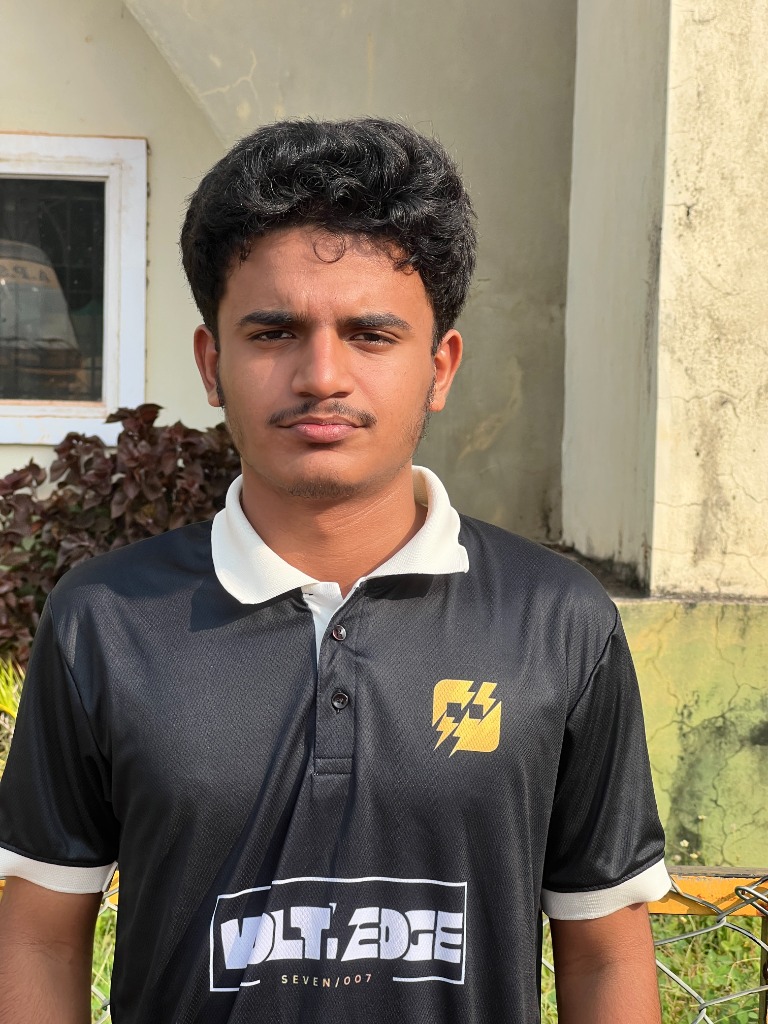
Shamveel Bukhari Khateeb
Acts as tactical guidance for the driver during matches, analyzing scoring routes and cycle timings. Concurrently leads visual documentation, capturing late-night build sessions, workshop breakthroughs, and competition footage.
- Real-time tactical path calculations prioritizing the shortest scoring route
- Timing charge collection and drop cycles to maximize endgame parking points
- Cinematography and video documentation for build logs and social media
- Workshop media coverage and student interview archiving
IIT Bombay Finals
The squad raising fists in celebration on the main stage upon winning the Community Champions title.
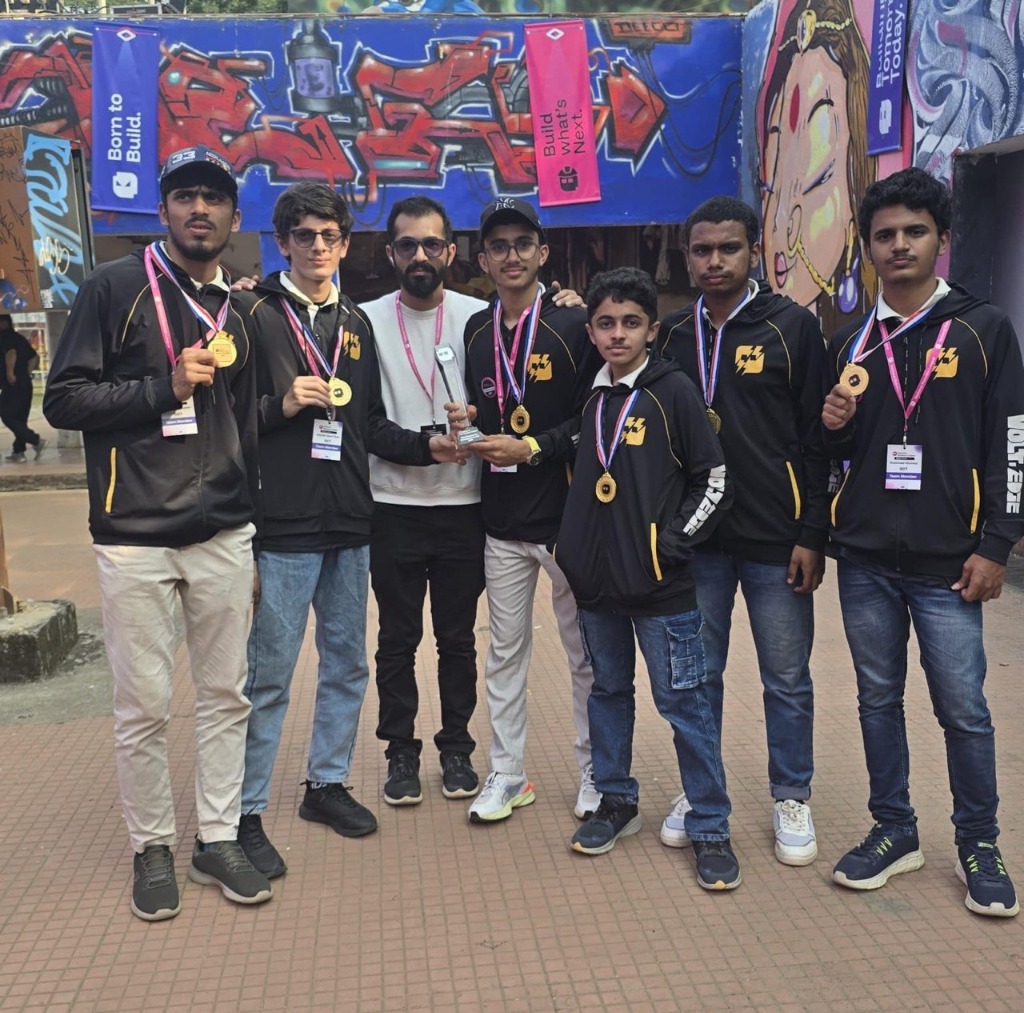
The squad with Founding Mentor Mr. Nuhail Damudi holding the official Community Champions Trophy.
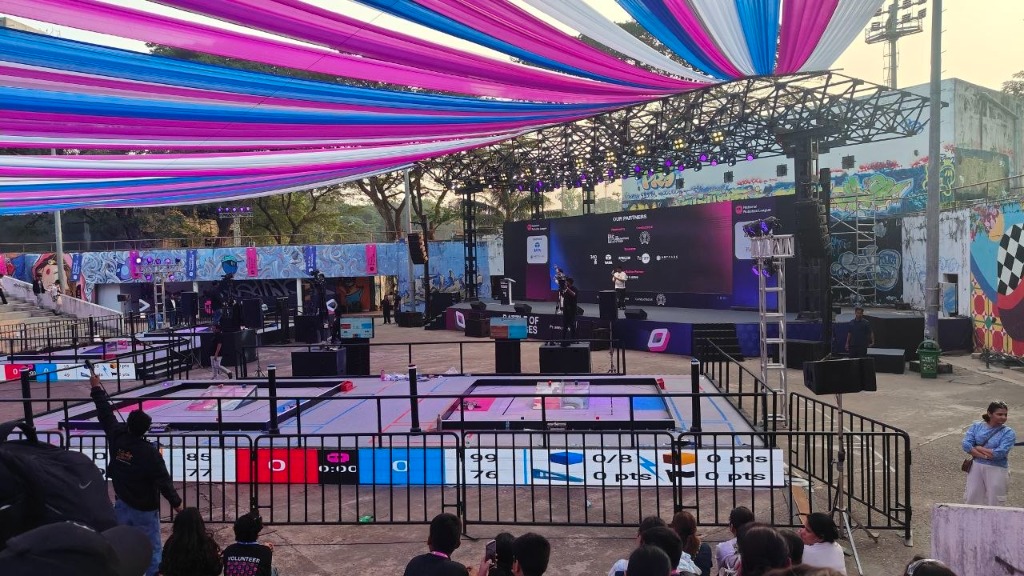
Main competition arena with overhead canopy, dual live scoreboards, and game field at IIT Bombay.
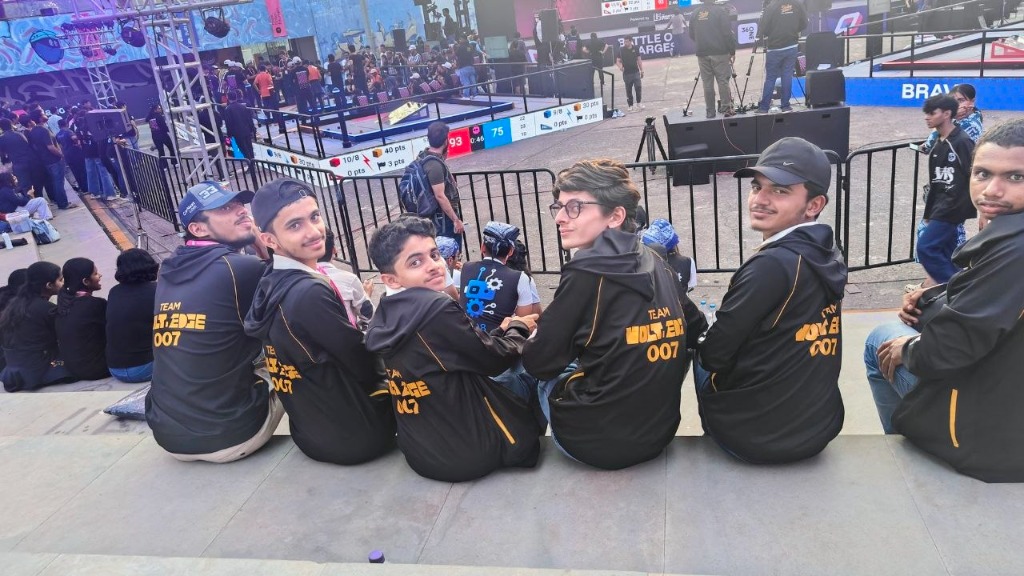
Squad seated in the arena amphitheater showcasing custom Team VoltEdge 007 gold back livery.
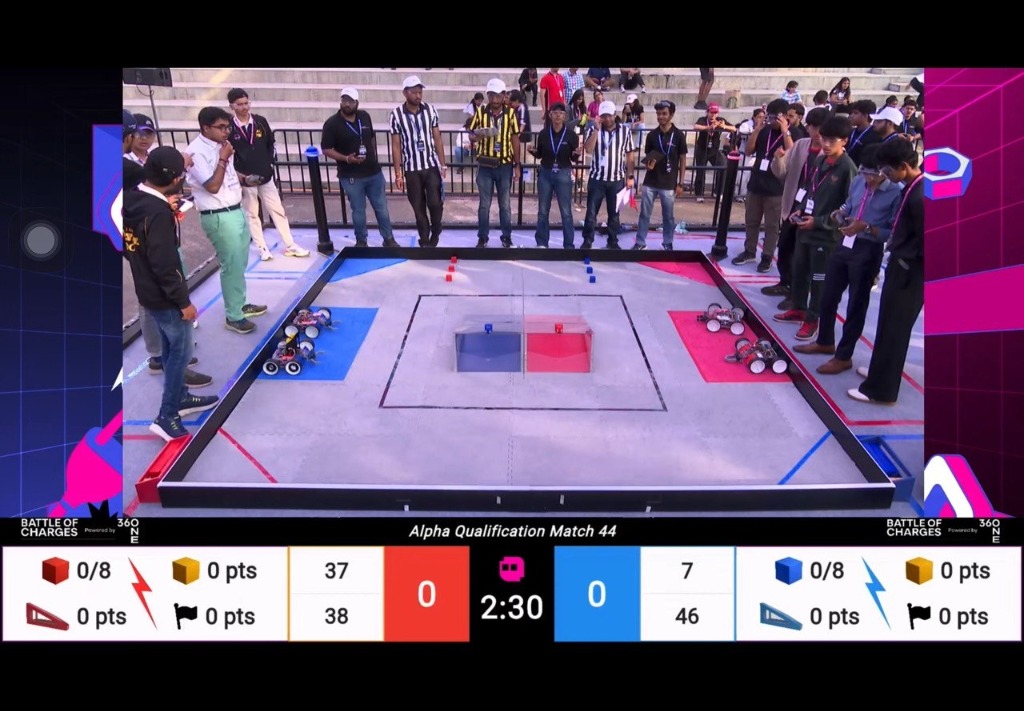
Live action view of Team VoltEdge operating EdgeBot in Match 44 inside the official 12x12 ft arena at IIT Bombay.
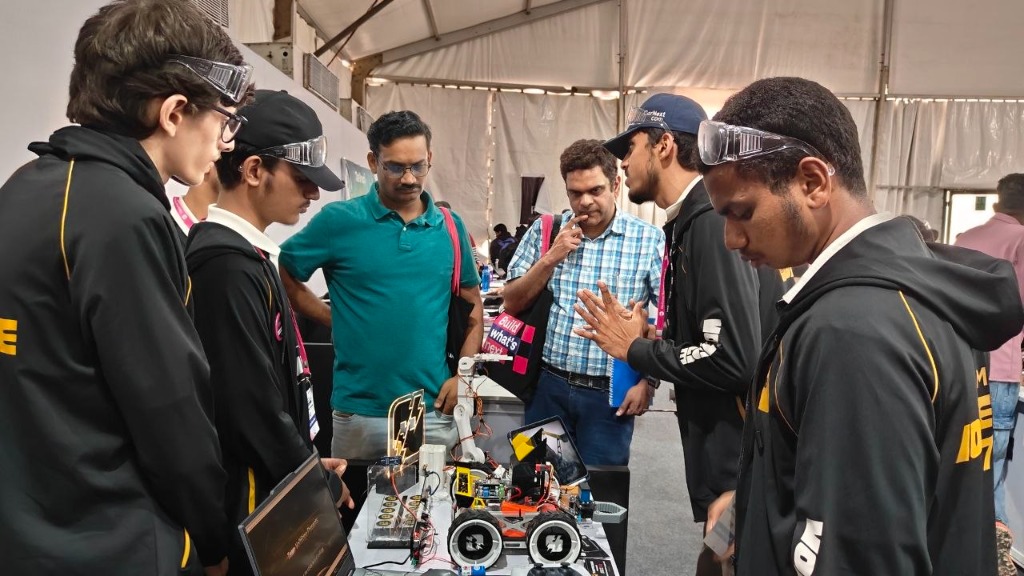
The squad in safety goggles presenting EdgeBot and technical innovations to competition judges.
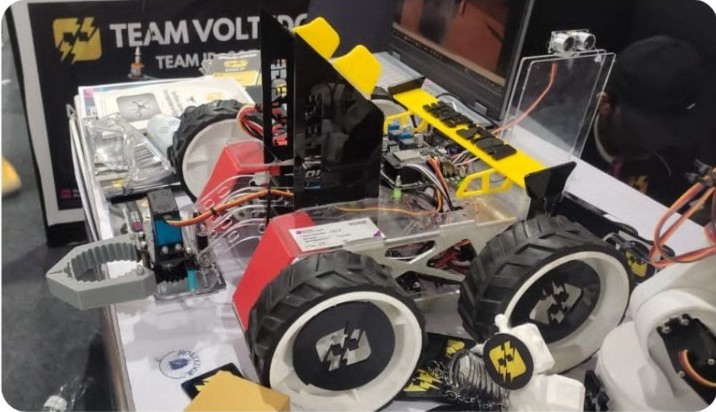
Close-up view of EdgeBot on the pit workstation with custom capped wheels, claw, and aero wing.
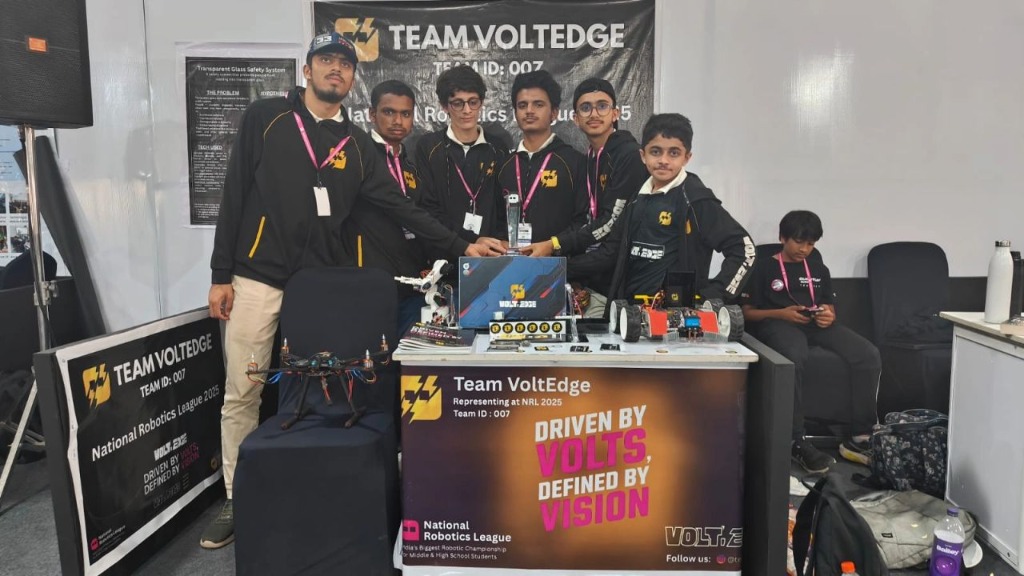
Displaying EdgeBot, Agri-Drone, Smart Glass Safety Wall prototype, and official banner.
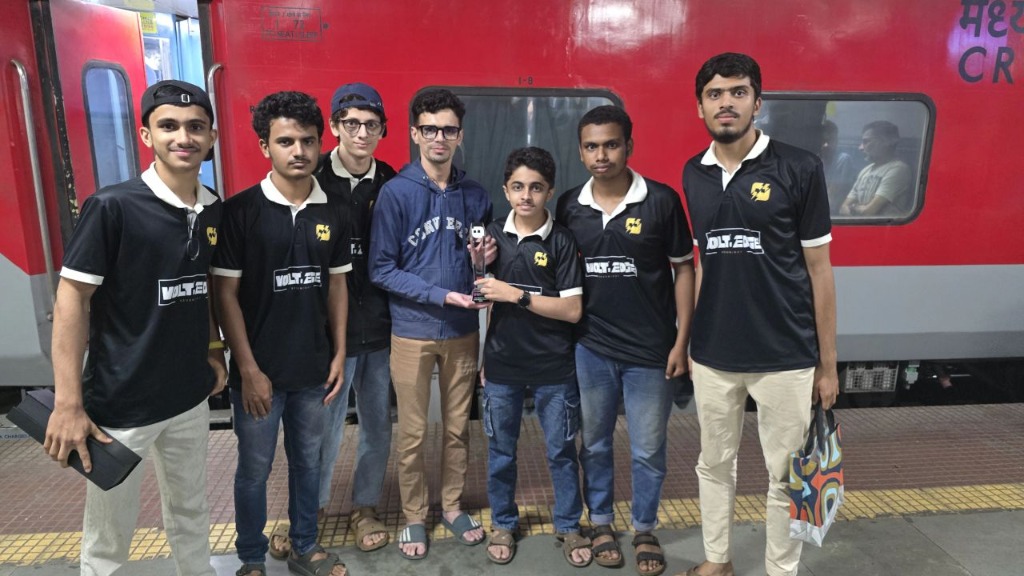
Our former teacher, who also met the team at the competition venue in Mumbai, bidding farewell during our return journey.
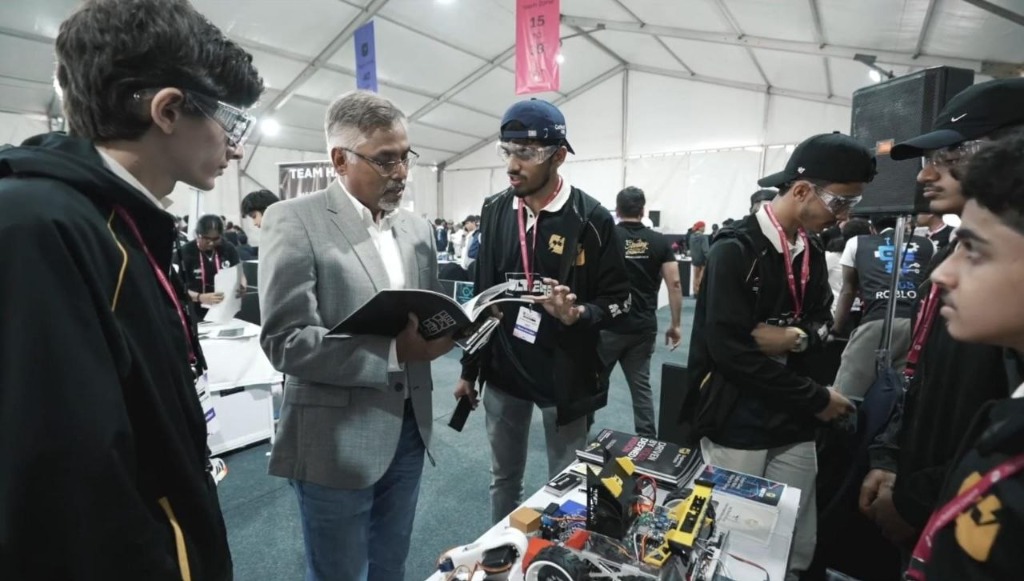
Mr. Samir Kumar, Country Manager of Amazon India, reviewing the printed portfolio and commending our work.
Mr. Nuhail Damudi
Introduced the team to Robotics in the 9th grade and provided foundational engineering guidance, strategic clarity, and mentorship.
Mr. Danish Gawai
Provided specialized mentorship on sensor data fusion, noise filtering on the infrared line array, and closed-loop heading corrections with the gyroscope.
Muhammed Ehab
Assisted our team in shooting videos and capturing photos.
Tactical Innovations & Builds
EdgeBot v1.0 — Combat & Arena Spec
High-torque, sensor-fused evolution of the standard NRL BaseBot platform.
Re-engineered from the ground up for the National Robotics League 2025 at IIT Bombay. Features a custom 3D-printed monster-truck shell, aerodynamic stabilizing wing, underglow surface illumination, and autonomous sensor array (IR + Gyro + Ultrasonic).
- Custom PWM analog arm elevation mapping replacing binary limit-switch jumps
- 5-second 'X' button safety delay for autonomous mode initialization
- Aerodynamic rear wing prevents rear lift during sudden high-torque acceleration
- Tactical downlights illuminate floor seams and assist visual diagnostics
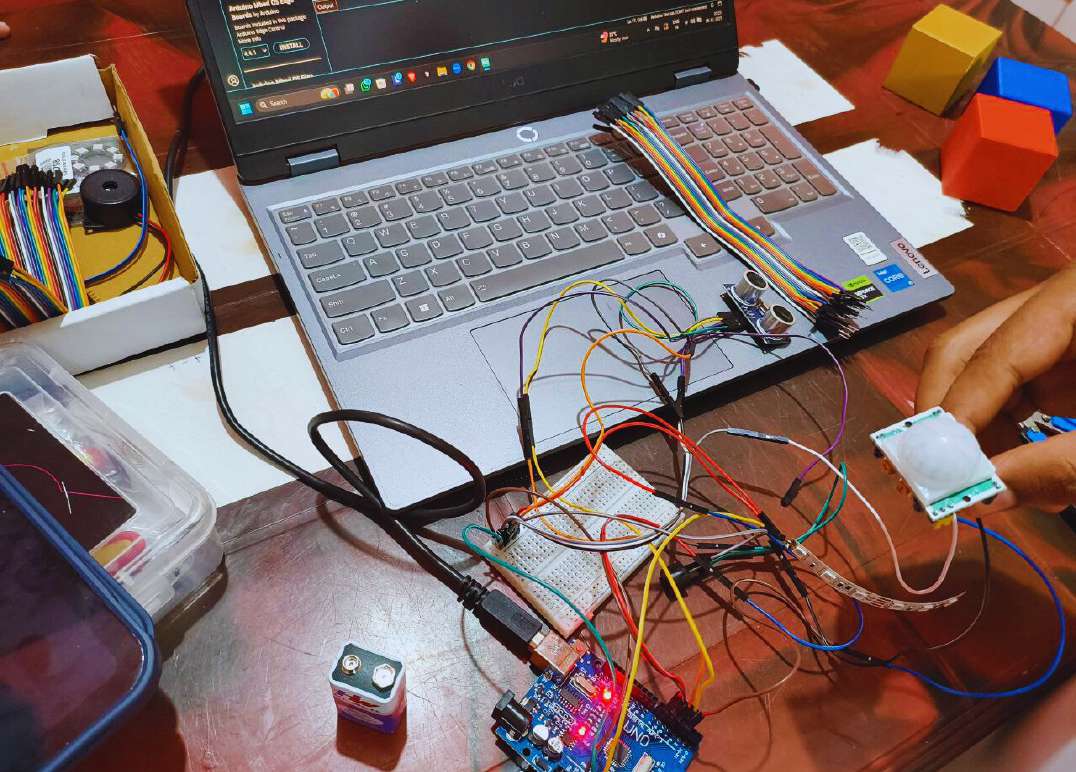
Smart Glass Safety Wall
Adaptive proximity-sensing safety illumination preventing glass partition collisions.
Built for the NRL Innovation Challenge. Solves pedestrian collisions into transparent glass walls in modern architectural spaces (schools, airports, corporate offices). Uses a multi-tiered sensing and processing model to warn occupants according to approach velocity.
- Distinguishes between safe walking and high-risk running approaches
- Architectural diffuser film preserves glass transparency when idle
- Validated under variable daylight and indoor illumination conditions
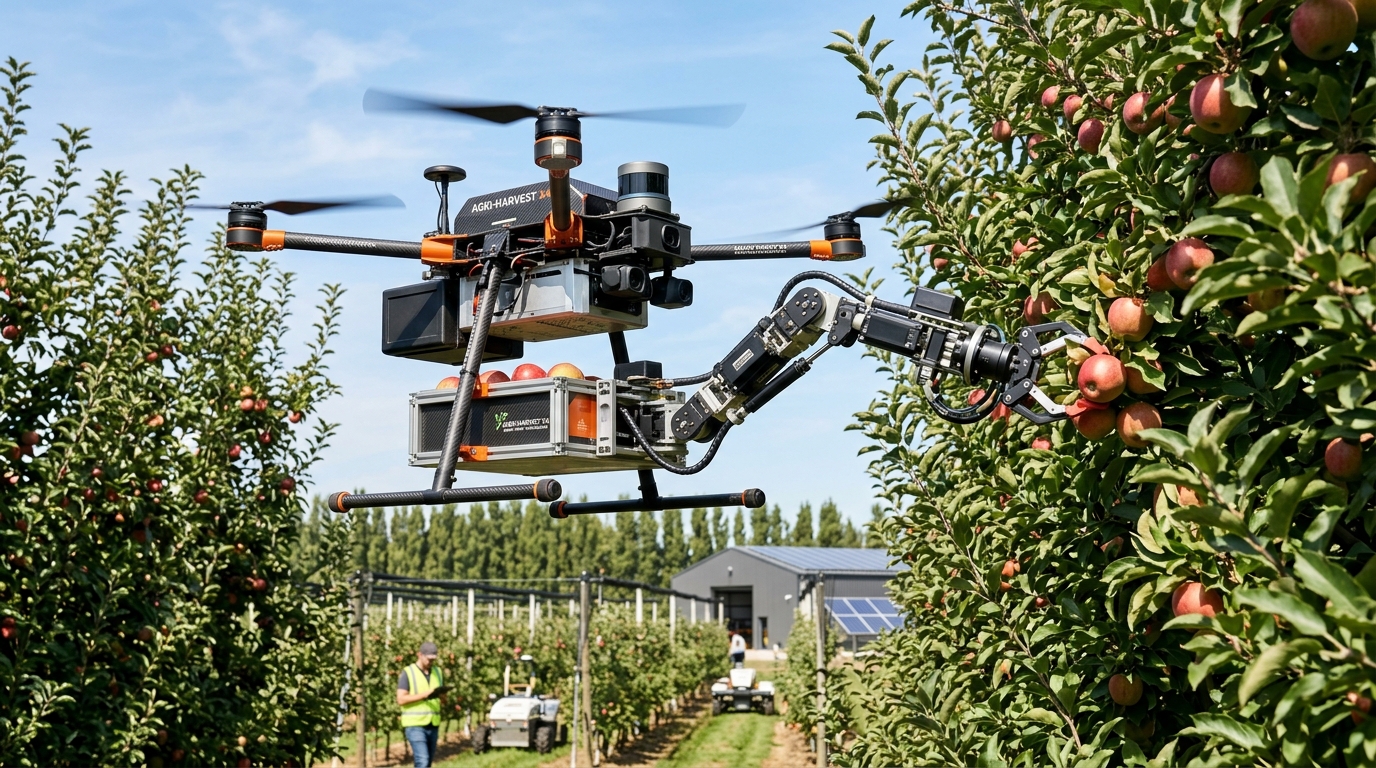
Remote Drone-Assisted Harvesting System
Autonomous aerial harvesting tool designed to safeguard agricultural labor on tall trees.
Conceived and developed by Omer Ruknuddin and Mohammed Zaid Fareed after direct field observation with regional coastal farmers. Solves the danger of manual climbing and ladder falls during fruit harvests.
- Won the prestigious Aspire Scientist Award for research clarity and social impact
- Eliminates life-threatening ladder climbing for rural plantation workers
- Modular gripper mechanism adaptable to multiple fruit profiles
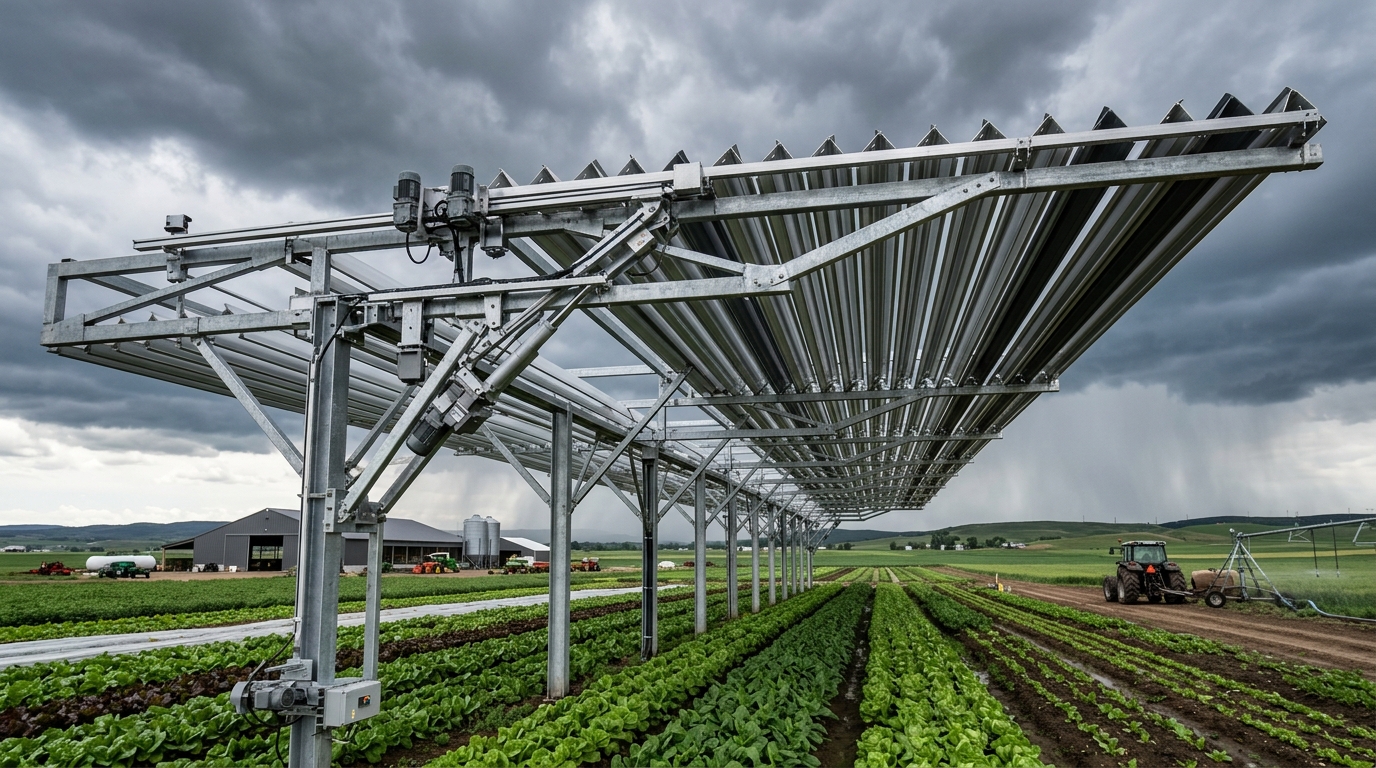
Automated Field Shutter System
Autonomous weather-reactive protective canopy defending crops against squalls.
Engineered by Mechanical Lead Ahmed Irfan Akrami. Deploys protective physical shutters over crops based on real-time wind and rain sensor thresholds, preventing monsoon damage without human intervention.
- Automatic deployment shields farmland from sudden torrential rain and gale winds
- Failsafe manual override with battery backup circuit
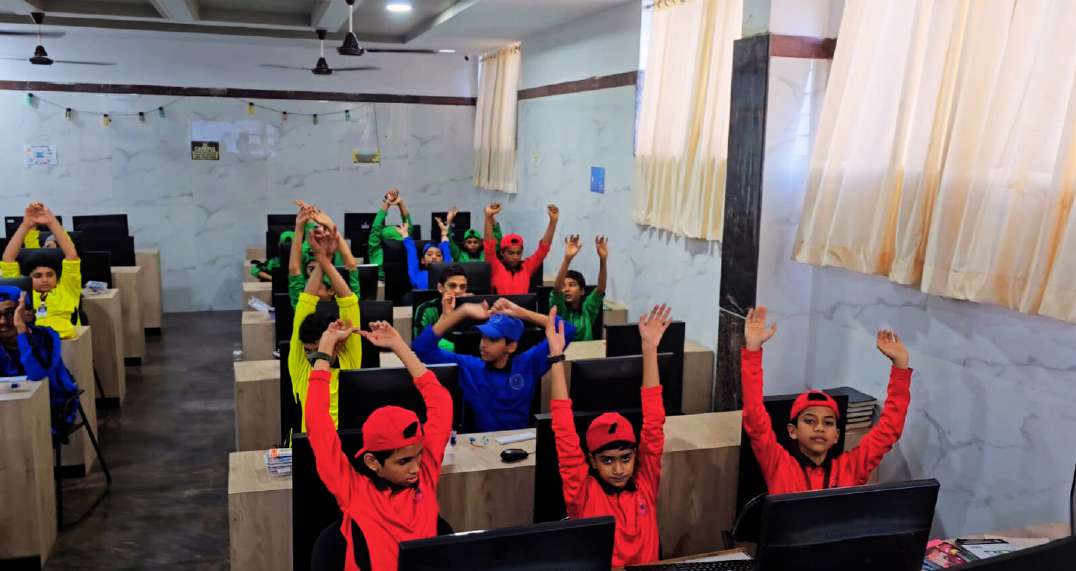
Ali Public School STEM Outreach & Basic Robotics Course
Demystifying robotics for 60+ middle and high school students in coastal Karnataka.
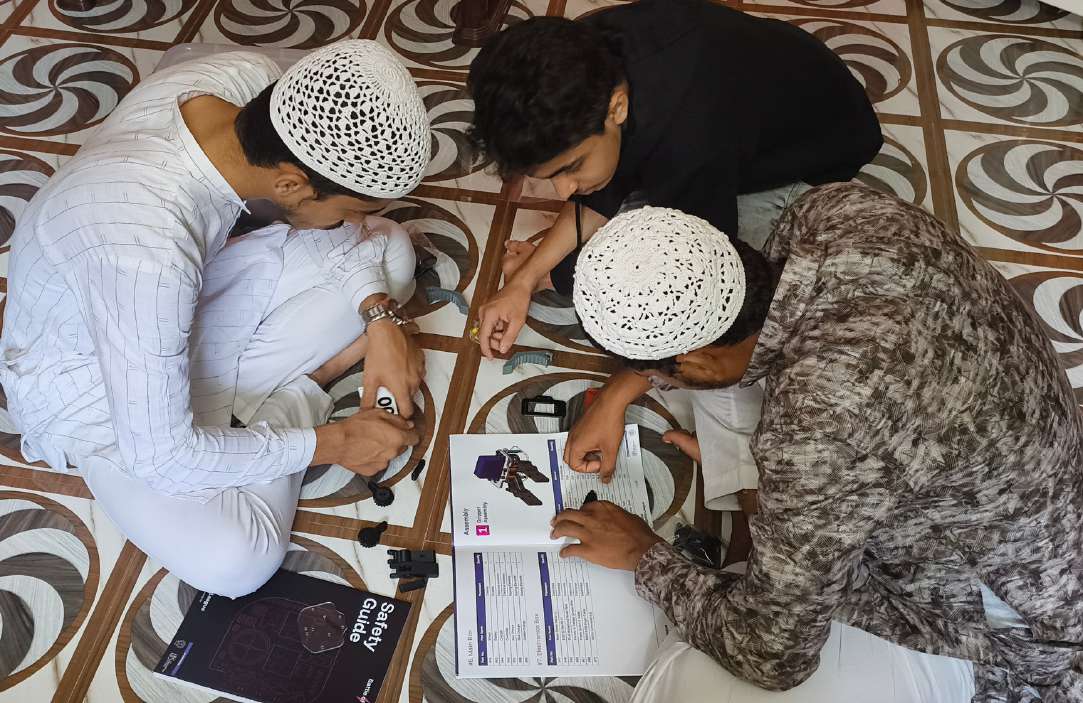
Comprehensive multi-tier outreach program in Bhatkal. Began with a 60-student interactive workshop on robotics history, sensors, and live robot operations, followed by a continuous hands-on course with custom Basic Robotics Kits distributed to learners.
- Distributed custom Basic Robotics Kits containing motors, chassis plates, and sensors
- Transformed robotics from an abstract textbook concept to a tactile reality
- Demonstrated that high schoolers from smaller towns can compete nationally at IIT Bombay
Certificates & Honors
Issued by Indian Institute of Technology Bombay & The Innovation Story • Swipe or click to browse members
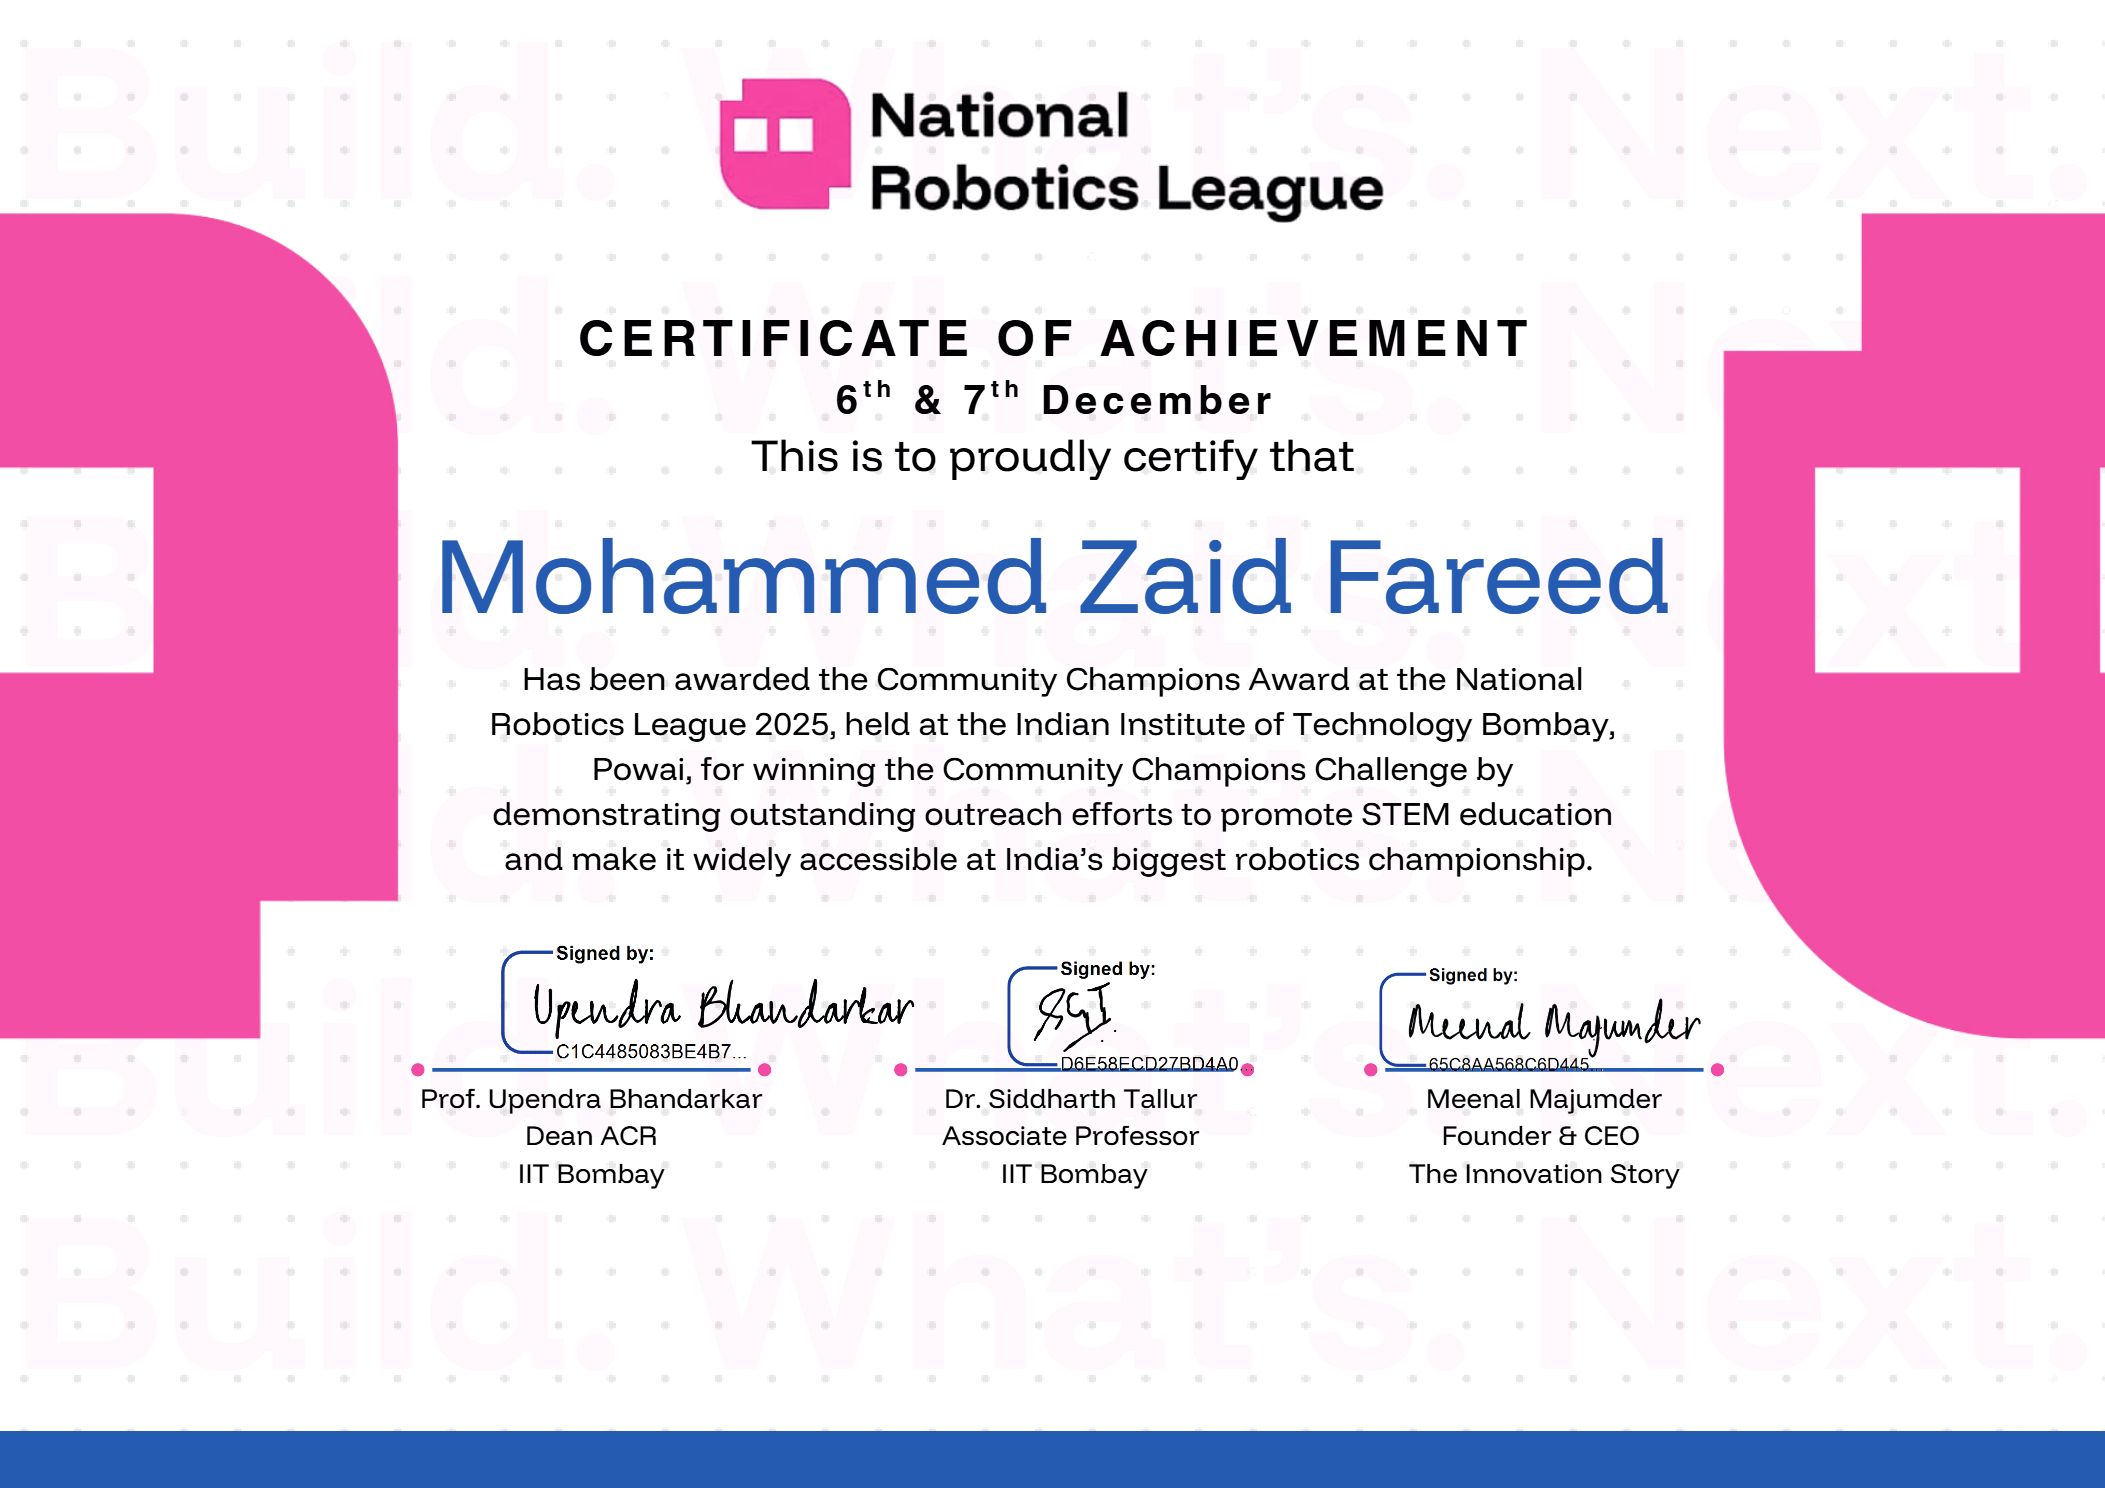
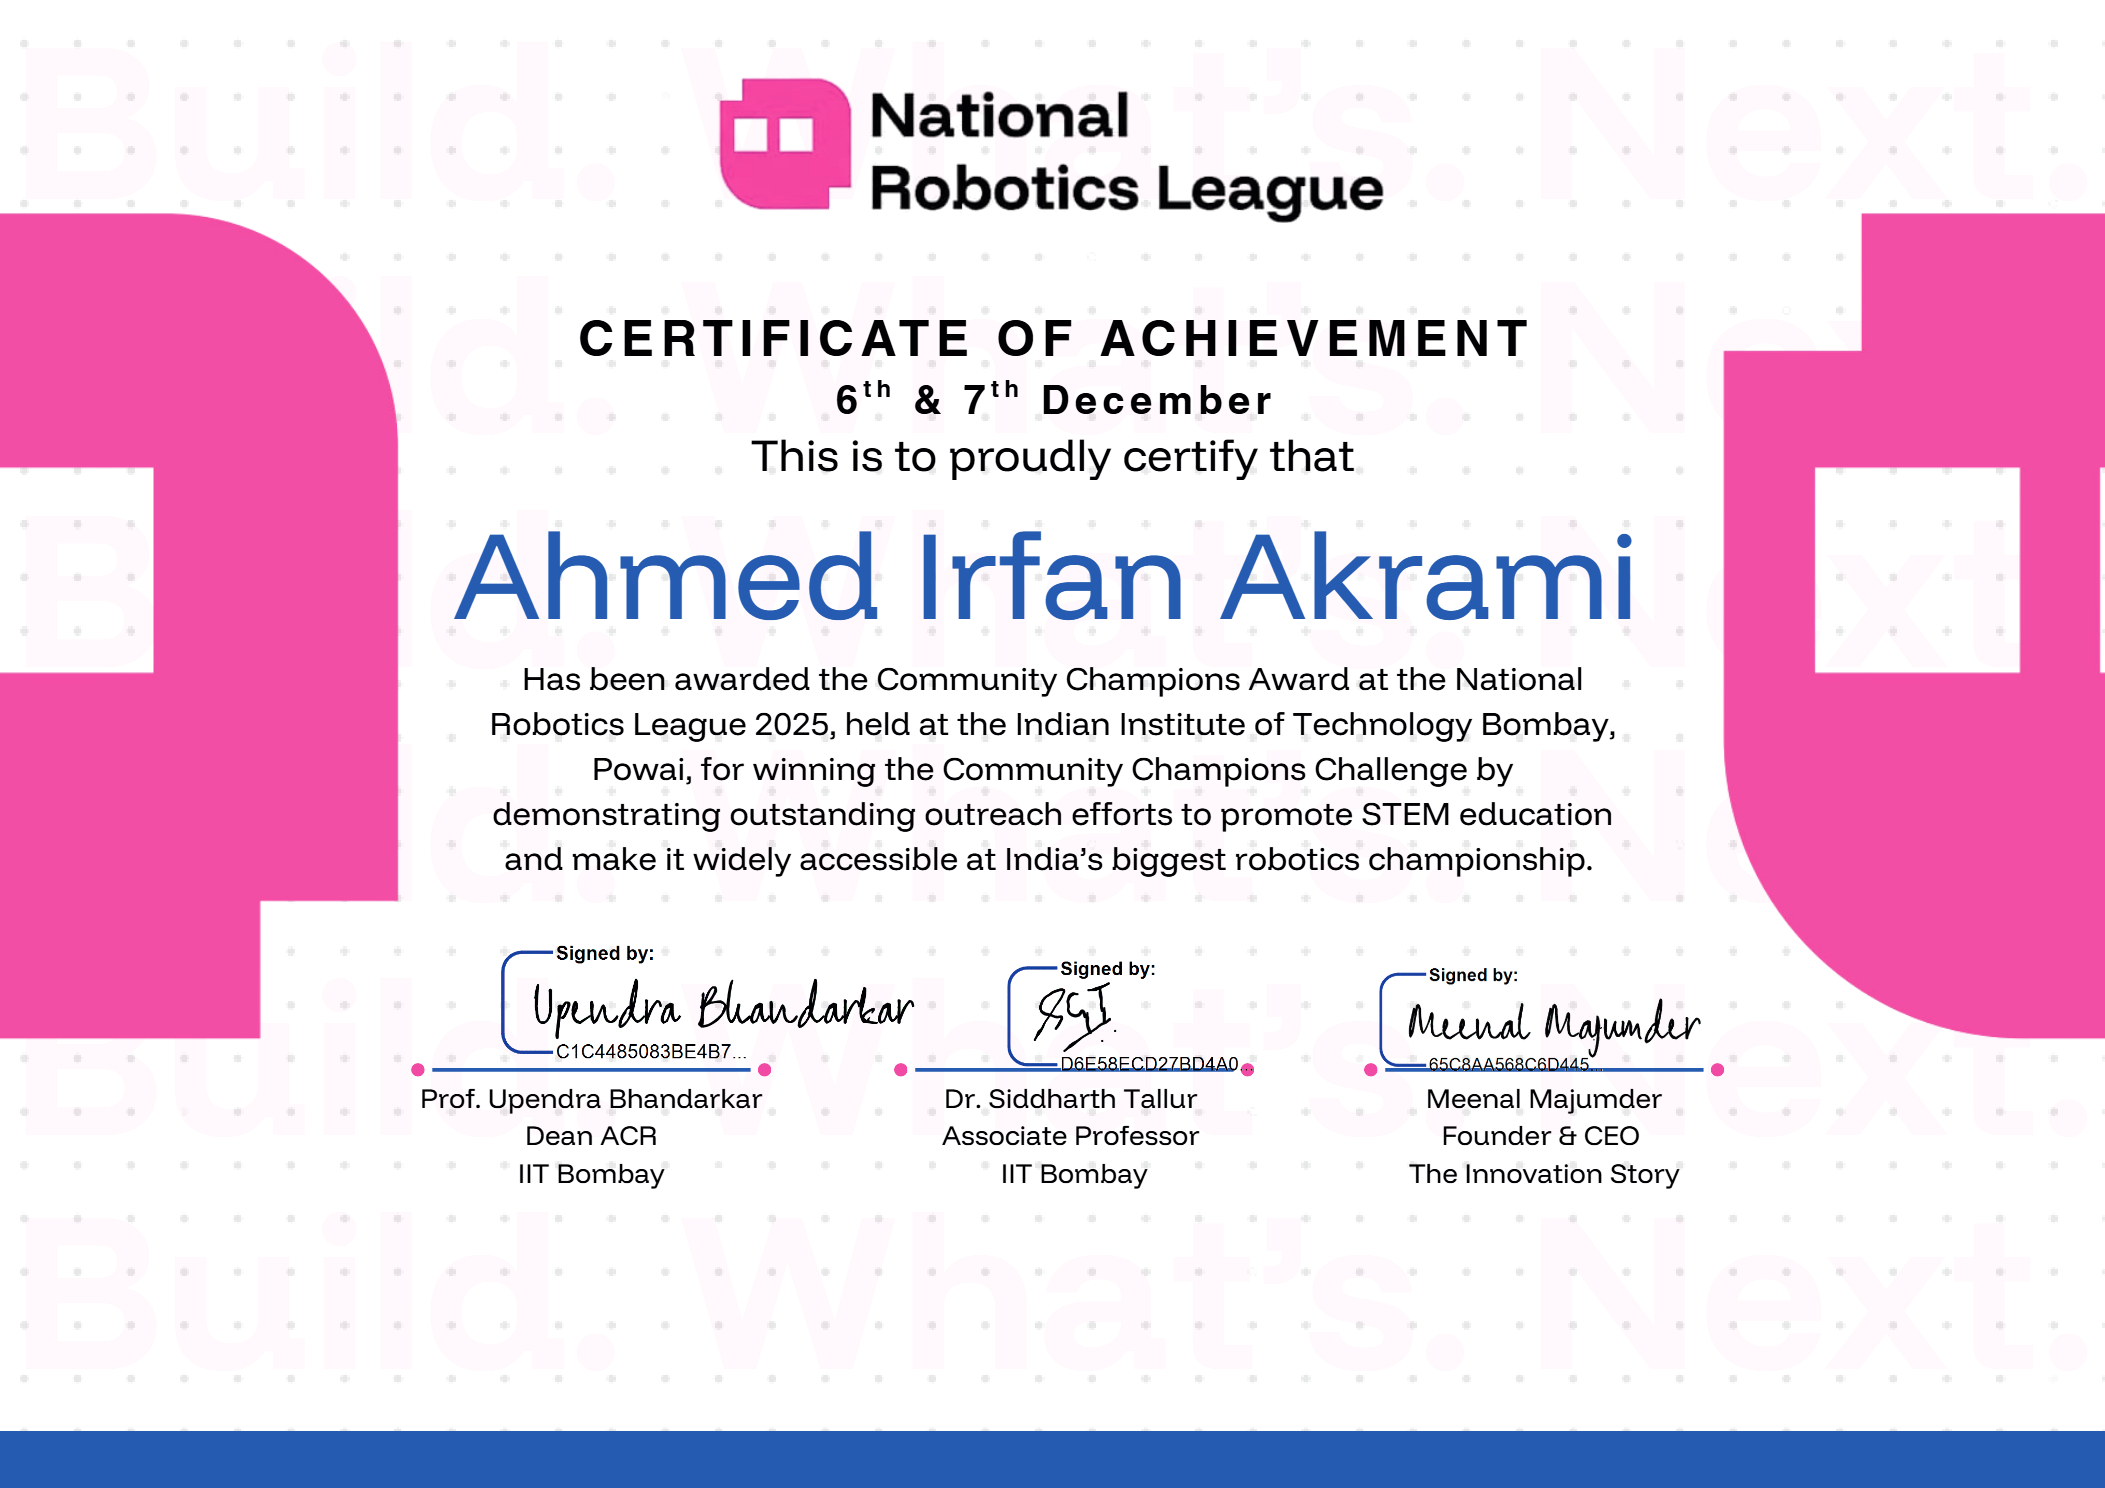
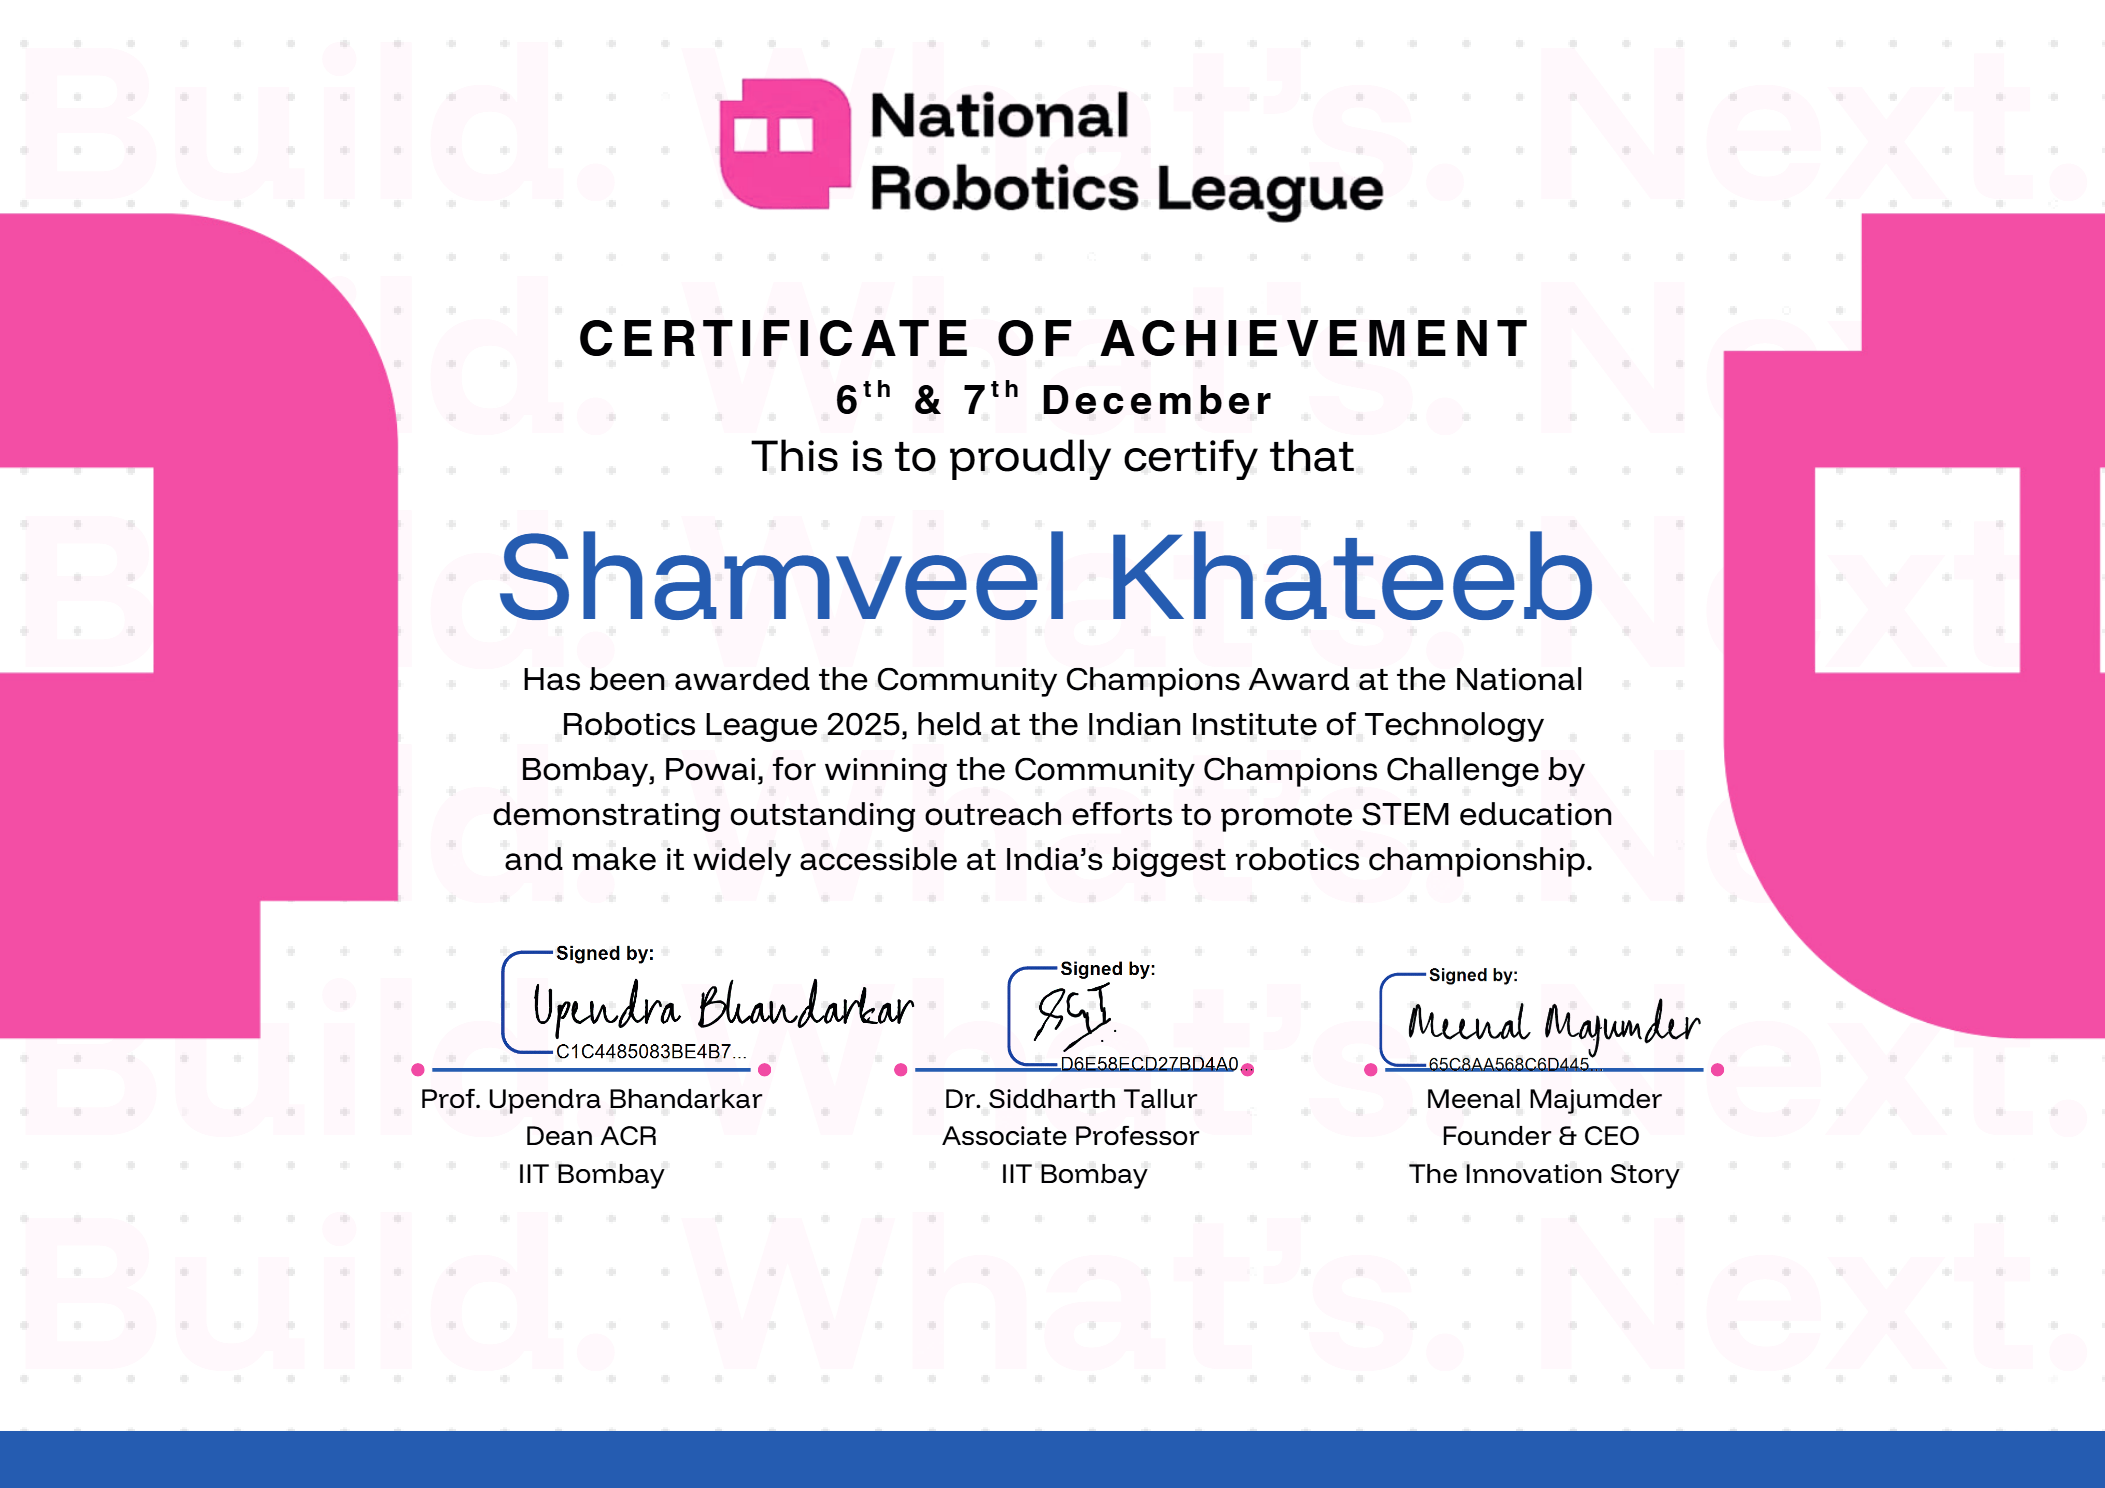
Social Growth & Telemetry
Cumulative digital impressions within two weeks
Unique non-duplicate audience nodes
External organic reach beyond existing network
Month-over-month engagement velocity
Viral authentic behind-the-scenes engineering reel
Over 85 percent of all viewership came from non-followers, demonstrating authentic organic discoverability without a single paid advertisement campaign.
The highest viewed reel was an authentic behind-the-scenes moment of the team observing other teams making videos, proving that engineering authenticity outperforms scripted public relations.
The VoltEdge Journey
The First Spark
Late-night message from Omer to Abdullah about the National Robotics League just 5 days before midterm exams. The vision to compete at IIT Bombay takes root.
Official Registration — Team ID: 007
Registered as Team VoltEdge one day before exam commencement. Zero hardware in hand, complete faith in execution.
BaseBot Kit Arrives in Bhatkal
Delivery of the raw components: acrylic chassis plates, DC motors, screws, MDD10 driver, and HEXA ESP32 board.
Continuous 6-Day Build Week
Intensive post-exam evening assembly sessions. Irfan aligned chassis, Zaid engineered wiring harnesses, Abdullah set up software environments, and Omer wrote first drive routines. Prototype completed Oct 27.
Ali Public School Workshop & NRL Challenge 1
Delivered keynote robotics workshop to 60 students. Same day: NRL announced the mandatory Team Reveal Video challenge.
Team Reveal Video Production
Complete video was edited and produced by Abdullah Saami Sada. Filmed on campus at dawn prior to departure, finalized for the official National Robotics League Team Reveal challenge submission.
Launch of Basic Robotics Course
Distributed hardware kits to Ali Public School students. Daily afternoon hands-on classes began, preparing them for their school science exhibition.
Autonomous System & Sensor Fusion Integration
Integrated self-purchased 5-sensor IR line array, gyroscope, and HC-SR04 ultrasonic sensor with guidance from Mr. Danish Gawai.
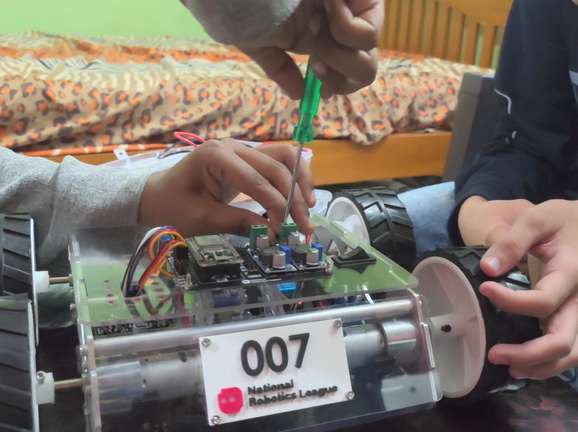
Smart Glass Wall Prototype Completed
Tested the 3-layer safety system for the NRL Innovation Challenge, validating approach speed detection.
Official Engineering Portfolio Submission
Submission of the exhaustive 60-page engineering documentation dossier and release of the official Robot Reveal Trailer.
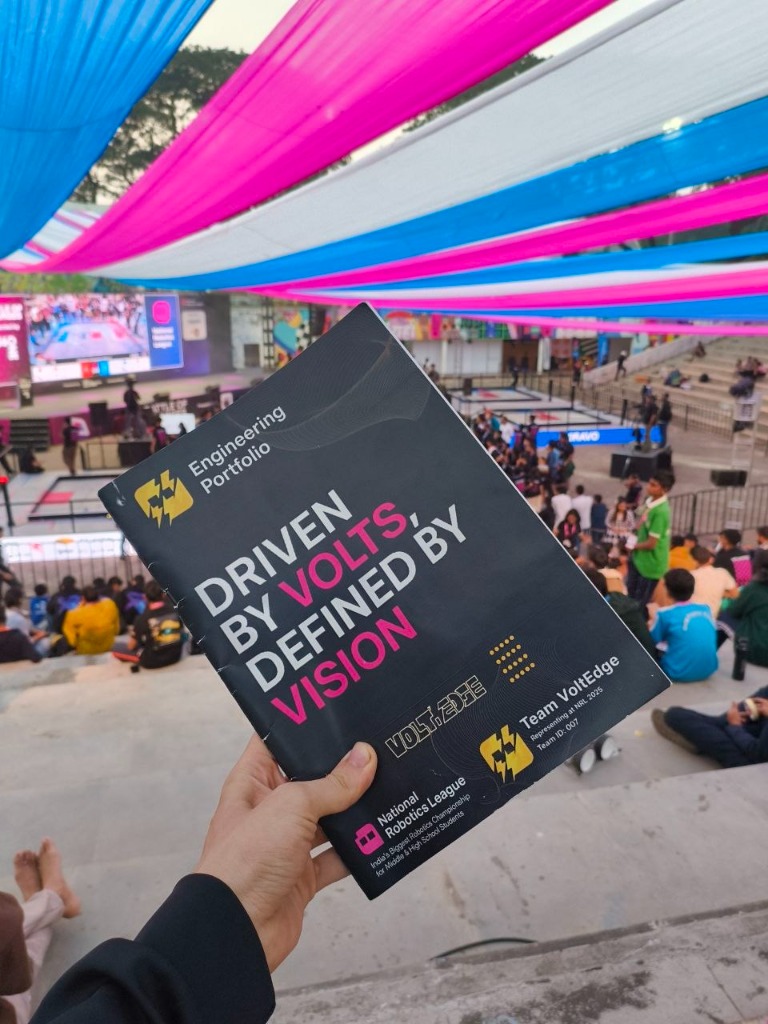
National Robotics League Finals — IIT Bombay
Team VoltEdge steps onto the national arena at IIT Bombay, executing competitive match rounds in the Battle of Charges arena against India's premier robotics squads.
Battle of Charges: Alpha Qualification Match 44
Team VoltEdge competing on the official 12x12 ft Battle of Charges field in Alpha Qualification Match 44 at IIT Bombay, executing offensive ball collection and ramp ascents in front of national match referees.
VIP Interaction: Amazon India Country Manager Mr. Samir Kumar
Mr. Samir Kumar, Country Manager & Vice President of Amazon India, visited the Team VoltEdge pit at the IIT Bombay National Finals. He personally reviewed our 60-page Engineering Portfolio and commended the squad's technical innovation, autonomous engineering, and youth robotics impact.
National Award Ceremony: Community Champions & Triple Nominations
Nominated for three prestigious national awards at the IIT Bombay National Finals: the Influenstar Award, the Brand Builder Award, and the Community Champions Award. Team VoltEdge was awarded the national title of Community Champions, taking home the official trophy.
E-Portfolio
Official Engineering Portfolio Dossier • Team ID 007